
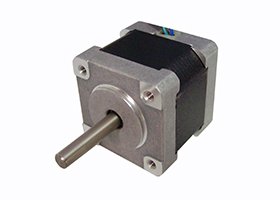
Stepper motors
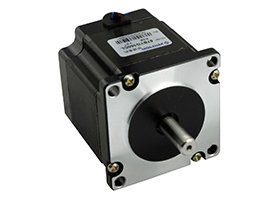
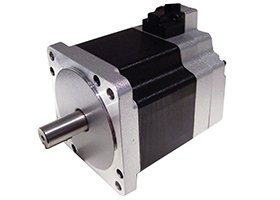
Two-phase hybrid stepper motor series
Beijing Senchuang Motion Control (SYN-TRON)- Step Angle
- 1.8°
- Example Model
- 42BYG250BK-0151
 0
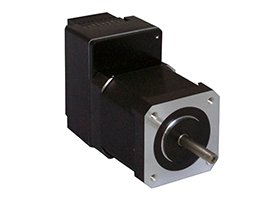
Manufacturer catalogue image · Series illustration
Catalogue series · Exact configuration and availability confirmed by the manufacturer.
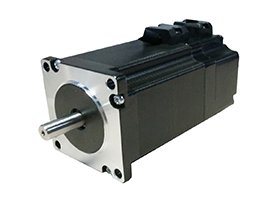
The ISS42 combines a 42 mm stepper motor and closed-loop electronics. The manufacturer’s November 2022 manual lists ISS42C250C and ISS42R250C with the same 0.54 N·m holding torque and 5 mm shaft. The important ordering difference is CANopen versus RS485/Modbus RTU—not a different torque rating. Both ISS42 entries require 24 V DC; the wider supply range elsewhere in the manual belongs to larger frames.
Retain the complete identifier in the inquiry. The first C or R after ISS42 identifies the communication family; the later C is the body-length code.
| ISS42C250C · catalogue code 001775 | The C version uses CANopen. The manual describes a factory bus rate of 250 kbit/s and node address 1, with parameter changes taking effect after repowering. Ask for the matching EDS file and communication manual for the supplied firmware. CANopen support alone does not prove compatibility with every motion-control mode in an existing controller. |
|---|---|
| ISS42R250C · catalogue code 001785 | The R version uses RS485 with Modbus RTU. The manual gives a factory rate of 115200 bit/s, address 1 and an 8-data-bit, no-parity, one-stop-bit format. For a multi-axis installation, allocate addresses before connecting identical factory-default units and verify the controller’s register implementation. Do not order R expecting the CANopen EDS configuration used by C. |
Values below refer to the listed 250C variants and the ISS42 dimensional drawing. The rear electronics extend beyond the motor body; leave additional room for connectors, wiring and cooling.
| Interface | Published value | What the buyer should check |
|---|---|---|
| Holding torque | 0.54 N·m | A static holding value; request the ISS42 curve at the required running speed |
| Shaft diameter | 5 mm | Coupling bore and shaft-end detail |
| Motor body L + rear section | 48 + 28 mm | 76 mm combined length shown by these sections, before shaft projection and cable clearance |
| Front face / mounting pattern | 42 mm / 31 × 31 mm | Four M3 mounting holes in the drawing |
| Rear envelope height | 59 mm | The integrated electronics do not fit entirely within the 42 mm face outline |
| DC supply | 24 V | Do not apply the ISS57/ISS86 24–60 V range to ISS42 |
A compact motor-and-drive assembly saves separate drive space, but the supply, motion profile and I/O still need an engineering match.
The manual’s displayed torque-speed plots are labelled for larger ISS56/57 variants, not ISS42. They cannot establish ISS42 running torque. Supply the moving load, transmission ratio, target speed and acceleration time, and request a curve for the exact ISS42 version at 24 V. The 0.54 N·m holding figure is not a full-speed torque promise.
The manual says the integrated unit has no built-in energy-dissipation control circuit and calls for an external dissipation module where regenerative energy is substantial. State whether the axis repeatedly decelerates a high-inertia load or is driven by the load. Have the supplier size and approve the supply and energy-handling arrangement; a nominal 24 V label alone does not settle it.
The electrical table gives 5 V TTL commands and 200 kHz maximum, while a later pulse-input paragraph says 500 kHz. These conflict, so this page does not promise 500 kHz. Give the required pulse rate and controller output level, and obtain the correct interface limit and wiring for the delivered revision before connecting the controller.
Published ambient operation is −5°C to +40°C with less than 80% RH and no condensation; cooling is by natural convection with forced air where necessary. The manual describes an optically isolated open-collector alarm output limited to 20 mA. Include the enclosure temperature and alarm input in the design. Closed-loop position control does not replace checking thermal limits or reporting an axis fault.
CATALOGUE OVERVIEW
SYNTRON ISS42 integrates a stepper motor and closed-loop control electronics into one assembly. The product line offers bus-controlled variants, including Modbus RTU and CANopen configurations. Its published supply is 24 V DC.
Confirm the exact communication suffix, motor torque, connector orientation and supported operating mode before selecting the assembly. An integrated drive reduces external wiring but requires appropriate cabinet power, grounding and thermal clearance. Send the travel profile and controller interface with your inquiry.
Model / series reference: ISS42
Specifications describe a series range; confirm which ratings apply together to the quoted model.
Confirm mounting and shaft dimensions against the drawing for the quoted configuration.
Stepper motors
Stepper motors
Stepper motors
Stepper motors
Keep your sourcing team on the same page.
We use cookies to keep this site working and measure website usage. Cookie & privacy details
 LinkedIn
 Facebook
 X
 WhatsApp
 Email