
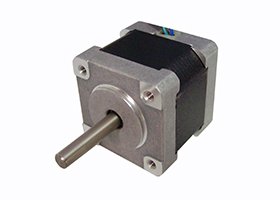
Stepper motors
Two-phase hybrid stepper motor series
Beijing Senchuang Motion Control (SYN-TRON)- Step Angle
- 1.8°
- Example Model
- 42BYG250BK-0151
 0
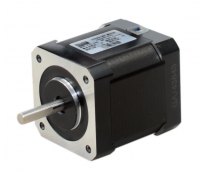
Manufacturer catalogue image · Series illustration
Catalogue series · Exact configuration and availability confirmed by the manufacturer.
MiGe uses the same F42-H34, F42-H40 and F42-H48 labels in separate two-phase open-loop and closed-loop tables, but the windings are not identical. The closed-loop page also adds an encoder and a rear enclosure. Specify which catalogue configuration is required; a shared F42 code does not by itself establish electrical or mechanical interchangeability.
All entries below have a listed 1.8° step angle and four motor leads. Holding torque is stationary torque, not an available running torque across the speed range. Resistance and inductance are kept with their own configuration.
| Short model | Configuration | Phase current | Holding torque | Resistance / inductance |
|---|---|---|---|---|
| F42-H34 | Open loop | 1.7 A | 0.31 N·m | 1.45 Ω / 2.2 mH |
| F42-H34 | Closed loop | 2.0 A | 0.30 N·m | 1.0 Ω / 1.6 mH |
| F42-H40 | Open loop | 1.7 A | 0.46 N·m | 1.75 Ω / 3 mH |
| F42-H40 | Closed loop | 2.0 A | 0.45 N·m | 1.2 Ω / 2.1 mH |
| F42-H48 | Open loop | 1.7 A | 0.56 N·m | 1.8 Ω / 3.6 mH |
| F42-H48 | Closed loop | 2.5 A | 0.55 N·m | 0.9 Ω / 1.8 mH |
The closed-loop encoder table lists 1,000 lines, a 5 V ±0.25 V supply and a 0–100 kHz response-frequency range. Its stated output-high level is at least 2.5 V and output-low level at most 0.3 V. Supply those specifications to the drive supplier and obtain compatible input and cable requirements. Do not infer a supported bus protocol or a complete position-loop performance guarantee from line count alone.
The motor wiring is black A+, green A−, red B+ and blue B−. The separate encoder cable uses red Vcc, black GND, green A+, brown A−, white B+ and grey B−. Red and black therefore have entirely different functions in the two cables. Keep the harnesses identified separately and verify the delivered connector pinout before applying power.
The open-loop drawing shows a 42.3 mm face, a 22 mm register, a 5 mm shaft projecting 24 mm and four M3 holes on a 31 mm square pattern. The closed-loop drawing retains that front interface but adds a rear enclosure shown as a separate 20 ±1 mm section. Its illustration shows a 39.1 ±1 mm motor section rather than dimensions for every table row, so obtain the selected model’s complete drawing rather than simply adding 20 mm to every nominal body length.
The open-loop F42 plots are labelled 24 V DC, 1.7 A and 4,000 microsteps. They show torque falling with speed. The closed-loop rows have different current and winding data; the open-loop plot is not a tested torque–speed curve for those motors. Request the chosen closed-loop motor/driver curve and acceleration limits for the application.
At 4,000 command steps per revolution, the geometric command increment is 0.09°, calculated as 360/4,000. That does not establish 0.09° absolute accuracy or repeatability. The source separately lists a 5% step-angle accuracy figure. Define the required measured shaft or mechanism position, load, direction changes and settling time instead of treating microstep count as an accuracy certificate.
The open-loop table gives mass as 210, 280 and 360 g for H34, H40 and H48. The closed-loop table retains a grams heading but prints 0.21, 0.28 and 0.36. The apparent unit inconsistency needs confirmation; these values should not be used to prove that adding the encoder has no effect on total mass. Obtain assembly mass and the final envelope for the selected version.
Specify supply voltage, configured current, maximum running speed, acceleration time, load inertia and the response to a following error or feedback loss. A motor with an encoder still needs a compatible drive and configured fault behaviour. The family also includes three-phase and larger-frame products; the F42 figures here are not specifications for those alternatives.
CATALOGUE OVERVIEW
Mige separates two-phase steppers, two-phase closed-loop steppers and three-phase steppers. The visible catalogue includes 42, 57, 86 and 110 references in the two-phase section and 42, 57, 60 and 85 entries in the three-phase section. These catalogue numbers do not establish holding torque or phase current. Specify open- or closed-loop control and obtain the matching torque-speed curve and driver settings.
Specifications describe a series range; confirm which ratings apply together to the quoted model.
Confirm mounting and shaft dimensions against the drawing for the quoted configuration.
Stepper motors
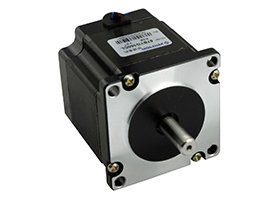
Stepper motors
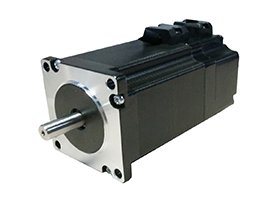
Stepper motors
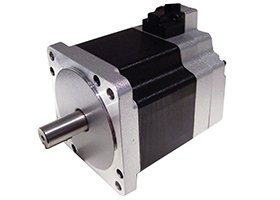
Stepper motors
Keep your sourcing team on the same page.
We use cookies to keep this site working and measure website usage. Cookie & privacy details
 LinkedIn
 Facebook
 X
 WhatsApp
 Email